Building systems that see, map and reason about the real world.
Computer vision and AI engineer with 4+ years of industry experience, including internships. I build 3D reconstruction, SLAM and sensor-fusion systems, native GPU engines for Gaussian splatting, and the vector-search and agent infrastructure that brings AI into production. I'm currently a Computer Vision AI/ML Engineer at IdeaBoxAI and lead developer of the official Python SDK for Actian VectorAI DB.
Open to computer vision, robotics, AI infrastructure and forward-deployed engineering roles across the US (on-site, hybrid or remote), remote roles from India, and global roles.
- App StoreVoxaVerse Beacon turns several iPhones into one synchronized RGB + LiDAR capture rig
- 84 µsmedian frame pairing between two iPhones over the network
- 32.97 dB4D Gaussian splatting on the N3V benchmark, on a laptop GPU
- v1.0.0official Actian VectorAI DB Python SDK, on PyPI on launch day
- 15×faster UV-texturing projection in a production 3D pipeline
What I've built
VoxaVerse: 4D volumetric video on Apple silicon
Capture, reconstruct and view walkable 4D scenes using only Apple hardware, with no cloud and no CUDA.
- Beacon (on the App Store) syncs several iPhones with Kalman-filtered clocks and closed-loop shutter-phase alignment. Median frame pairing is 84 µs; ChArUco calibration reaches 0.389 px reprojection error.
- Engine: native C++/Metal 4D Gaussian splatting. 32.97 dB PSNR on N3V (published state of the art is 33.57 dB), with 151 FPS mean GPU playback on an M3 Pro.
- Open format: the vvSpec capture specification, with a Rust converter and an independent Swift validator.
- I architected it alone and built it by directing AI coding agents (Claude Code, Codex) against measured gates.
- C++
- Metal
- Swift
- AVFoundation
- Rust
- WebGPU
- 3DGS / 4DGS


Actian VectorAI DB: official Python SDK
I'm lead developer of actian-vectorai-client, the official Python SDK for Actian VectorAI DB. It shipped at v1.0.0 on PyPI on the product's launch day, April 28, 2026.
- Sync and async clients over gRPC and REST
- TLS, retries and API-key authentication
- A filter DSL and hybrid fusion for search
At launch, Actian reported more than 22× the throughput of leading open-source vector databases at 10M vectors.
Agentic AI: MCP servers and enterprise integrations
Connecting AI agents to the systems enterprises actually run.
- An MCP server with OAuth 2.1. I fixed a failed demo's agent routing, and the agent now picks the right tool 31/31 times.
- A legacy ERP connected to GraphRAG, with 5,108 relationships inferred from undeclared keys.
- Warm schema calls cut from about 2 s to 18 ms.

WinPlay: AirPlay 2 for Windows, from scratch
mDNS, HomeKit pairing, RTSP/RAOP, a PTP clock for multi-room sync, ALAC and H.264 mirroring, all in .NET 8. About 850 downloads, with issues filed by real users.
360° video to 3D, SLAM and sensor fusion
Production 3D capture for architecture and construction clients. Promoted from CV intern to software engineer to computer vision engineer.
- 90% background-noise reduction with a 3D voting algorithm
- UV-texturing projection 15× faster on 10M+ point scans
- 25% better SLAM trajectory accuracy from LiDAR, RGB-D and IMU fusion
Axhara: encrypted phone-to-USB input device
On-device speech recognition sent over end-to-end-encrypted Bluetooth LE to an ESP32 dongle that types as a USB keyboard. Embassy Rust firmware, a pairing handshake modelled in Tamarin and ProVerif, and apps for iOS and Android.
Computer vision research
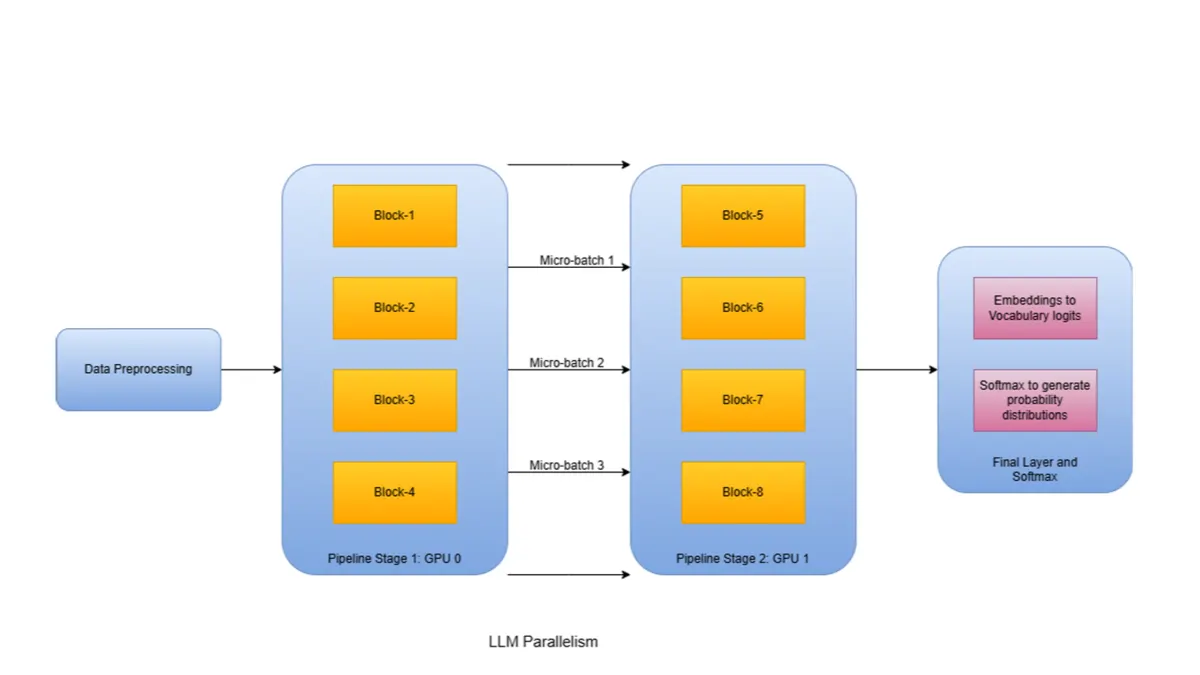
Pipeline parallelism for LLMs
GPipe-style training of GPT-style transformers on two RTX 2080 Ti GPUs, built on PyTorch's pipeline APIs. 42% higher throughput, with per-GPU memory down from 90% to 65%.
- PyTorch
- CUDA
- Distributed
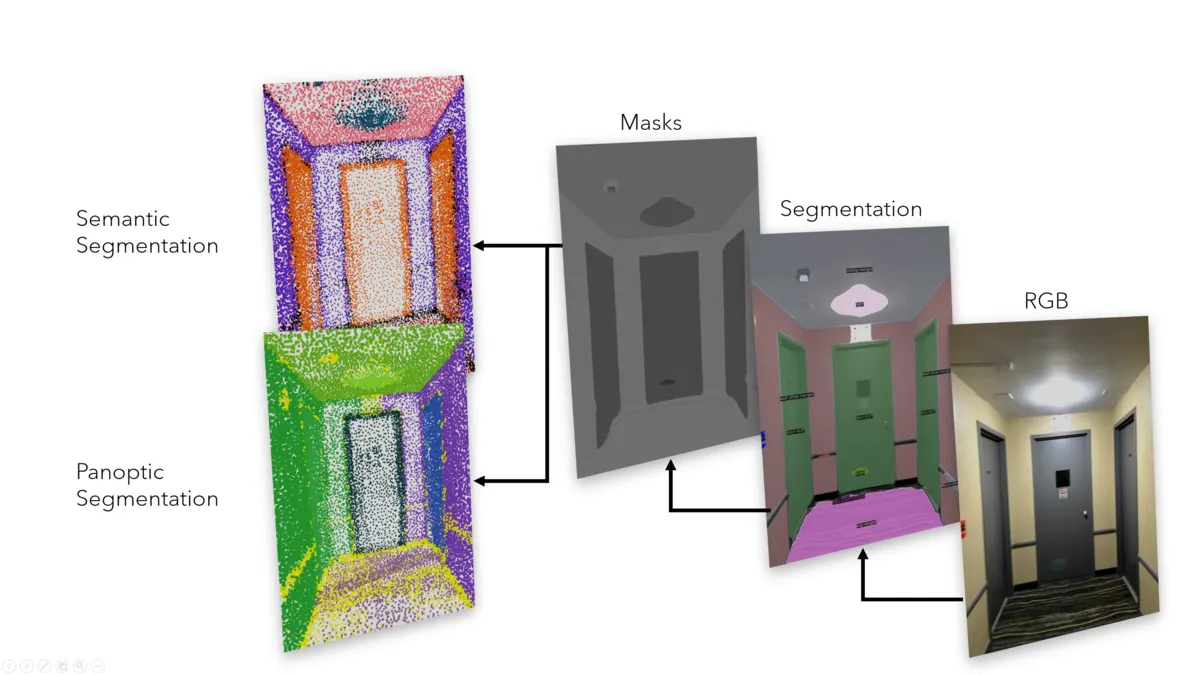
Panoptic 3D point-cloud segmentation
iPhone LiDAR scans captured with RTAB-Map, with OneFormer masks (133 categories) fused into 3D by multi-view back-projection and voting.
- OneFormer
- Open3D
- RTAB-Map
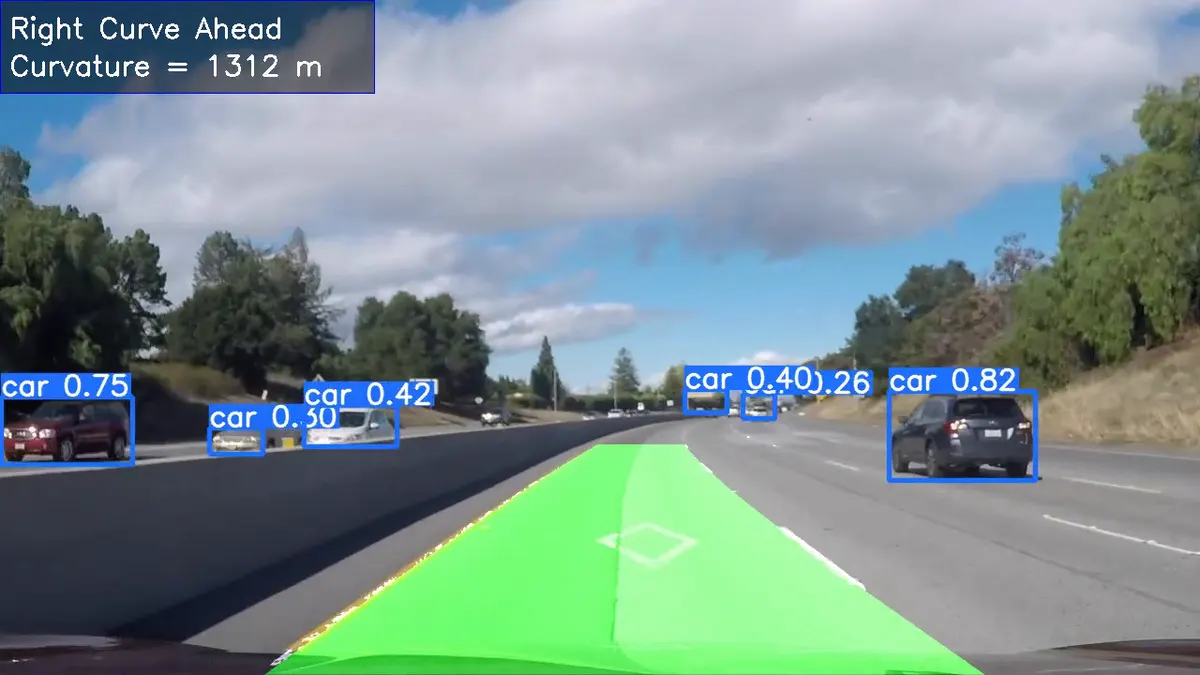
Vehicle RoadSense ADAS
YOLOv8 detection combined with classical lane finding (calibration, bird's-eye warp, polynomial fit), running at 30+ FPS.
- YOLOv8
- OpenCV
- Python
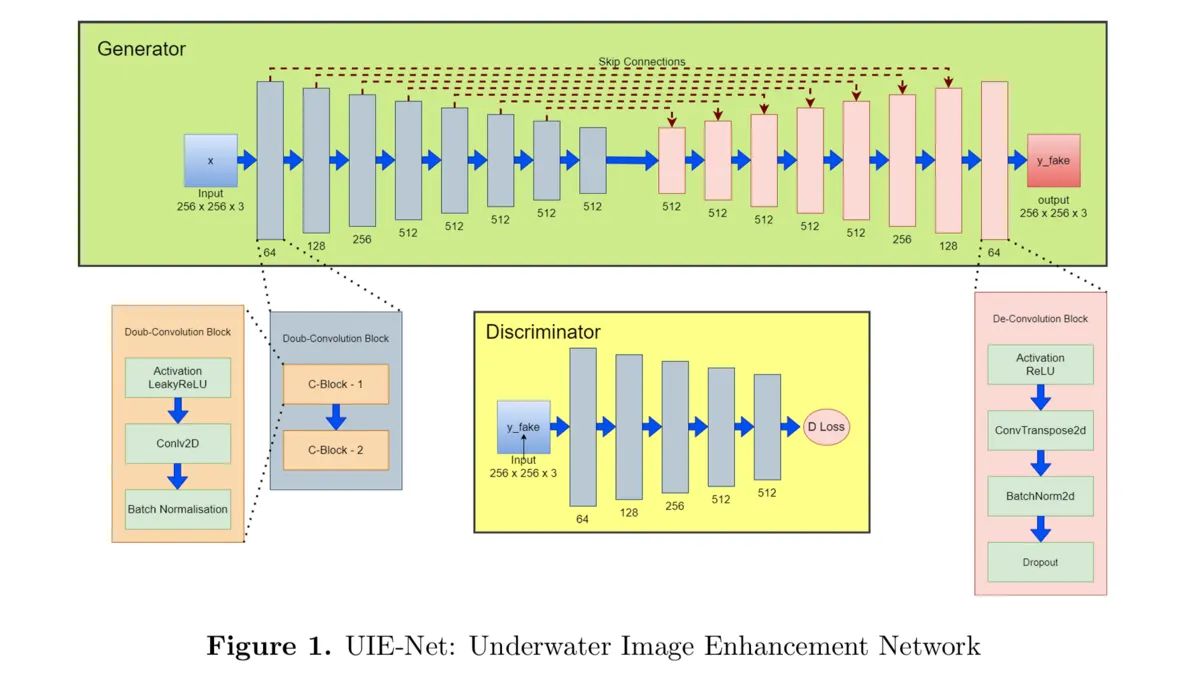
UIE-Net: underwater image enhancement
A GAN for autonomous underwater vehicles that improved visibility by 60–75%. Accepted at GC-RDCT 2021.
- GANs
- PyTorch
Where I've worked
Computer Vision AI/ML Engineer
- Lead developer of Actian VectorAI DB's official Python SDK, which shipped on PyPI on launch day.
- MCP agents and legacy-ERP GraphRAG integrations for IdeaBoxAI's agent platform; inference with NVIDIA Triton, vLLM and TensorRT.
Computer Vision AI/ML Engineer Intern
- Construction-progress AI on NVIDIA VSS and NeMo with Omniverse digital twins; ORB-SLAM3 and TensorRT on Jetson Orin for site perception.
3D AI Lead Engineer
- Text-, image- and video-to-3D generation (NeRF, photogrammetry), plus multi-GPU training and hosting that cut compute cost 30% in real-world testing.
Computer Vision Engineer
Promoted from CV Intern to Software Engineer to CV Engineer.
- 360° video to 3D with 90% noise reduction, UV texturing 15× faster, SLAM sensor fusion with 25% better trajectory accuracy, and on-device capture at 10–15 FPS.
Research Project Intern and Project Trainee
- UIE-Net underwater enhancement (GC-RDCT 2021) and computer-vision scoring of neurosurgical micro-suturing.
What I work with
3D vision & robotics
- Photogrammetry
- SfM / MVS
- COLMAP
- SLAM
- ORB-SLAM3
- Sensor fusion
- Calibration
- Point clouds
- 3DGS / 4DGS
- NeRF
Computer vision & ML
- PyTorch
- OpenCV
- YOLOv8
- Mask R-CNN
- OneFormer
- DINOv2 / CLIP
- VLMs
- MLX
GPU, inference & edge
- Metal
- CUDA
- TensorRT
- ONNX
- Triton
- vLLM
- Jetson
- WebGPU
NVIDIA AI stack
- NeMo
- VSS
- Omniverse
- Triton
- TensorRT
AI infrastructure & agents
- Vector databases
- FAISS / HNSW
- Milvus / Qdrant
- gRPC / Protobuf
- MCP
- LangGraph
- RAG / GraphRAG
- FastAPI
Languages
- Python
- C++
- Swift
- Rust
- TypeScript
- C#
Education & certifications
M.S., Computer Science
Case Western Reserve University, Cleveland, OH
High-performance systems for AI, computer vision, image processing, robotics
B.E., Computer Science & Engineering
KLE Technological University, Hubballi, India
CGPA 8.09/10, Center of Excellence in Visual Intelligence
Certifications
- NVIDIA DLI: Accelerated Computing with CUDA C/C++ (2025)
- The Linux Foundation: Developing Secure Software, LFD121 (2025)
- IIIT Hyderabad: 3D Computer Vision (2020)
Let's build something that sees.
I'm open to computer vision, robotics, AI infrastructure and forward-deployed engineering roles. I'm on F-1 STEM OPT and authorized to work in the US now; I'll need H-1B sponsorship in the future.